I am a second-year Ph.D. student in Computer Science at Arizona State University, advised by Prof. Nakul Gopalan.
I work on learning algorithms that help robots acquire skills beyond their training distribution.
In particular, I am interested in policies that can retain useful information over long horizons and transfer learned skills across different robot embodiments.
Highlightsbolt
Keyframe Mnemonics trains on short demonstrations of memory-intensive tasks and learns horizon-invariant policies that generalize to much longer horizons at test time.
XMoP learns a neural motion planning policy that generalizes zero-shot across the configuration spaces of unseen robotic manipulators.
🎉 Technical report on AI safety evaluation for AVs accepted at SAE WCX 2024.
Research
Lately I've been thinking about cross-embodiment generalization, long horizon memory for robot policies, and post-training policy improvement methods. Here are some papers that shows my latest research. Some of my favorites are highlighted!
Can the General Public Teach Robots Using Vision-Language-Action Models? A Study on the Utility of VLAs and Data Collection Interfaces for Diverse User Populations
Weiwei Gu*, Prabin Kumar Rath*, Prabhath Adireddi, Kartikay Milind Pangaonkar, Anmol Gupta, Anant Sah, Anudeep Sai Gottapu, Nakul Gopalan In Submission, 2026
User study of younger and older adults commanding a state-of-the-art VLA and teaching it new tasks via GELLO and VR teleoperation. Our study shows that users prefer performing tabletop tasks themselves over instructing the VLA, and that difficult tasks remain challenging to teach regardless of the teaching interface.
Self-Supervised Keyframe Discovery for Horizon-Invariant Behavior Cloning Prabin Kumar Rath, Omkar Patil, Nakul Gopalan Neural Information Processing Systems (NeurIPS), 2026 CoRL RoboMem Workshop, 2026
We introduce a novel self-supervised algorithm that discovers sparse, decision-relevant keyframes for memory-intensive behavior cloning without requiring any additional keyframe annotations. Our policy exhibits horizon invariance, maintaining strong performance on test horizons that are significantly longer than those seen during training.
StageCraft: Execution Aware Mitigation of Distractor and Obstruction Failures in VLA Models
Kartikay Milind Pangaonkar*, Prabin Kumar Rath*, Omkar Patil*, Nakul Gopalan International Conference on Intelligent Robots and Systems (IROS), 2026 IROS WORLDS Workshop, 2026 (Spotlight)
Training-free approach to improve pretrained VLA policy performance by manipulating the environment's initial state using VLM-based in-context reasoning.
We evaluate performance of state-of-the-art VLA models with StageCraft and show performance improvement across three real world task domains involving diverse distractors and obstructions.
Factorizing Diffusion Policies for Observation Modality Prioritization
Omkar Patil, Prabin Kumar Rath, Kartikay Milind Pangaonkar, Eric Rosen, Nakul Gopalan International Conference on Robotics and Automation (ICRA), 2026 RSS RoboReps Workshop, 2025
Theoretical framework to learn action diffusion models without the need to jointly condition on all input modalities. Our method is robust to deploy against visual distractors, camera occlusions, and appearance changes, maintaining strong performance where standard diffusion policies fail catastrophically.
XMoP: Whole-Body Control Policy for Zero-shot Cross-Embodiment Neural Motion Planning Prabin Kumar Rath, Nakul Gopalan International Conference on Robotics and Automation (ICRA), 2025 RSS Workshop on Embodiment-Aware Robot Learning, 2024
A novel neural policy that solves motion planning problems zero-shot for unseen robotic manipulators. We demonstrate for the first time that configuration-space behavior cloning policies can be learned without embodiment bias and that these learned behaviors can be transferred to novel unseen embodiments in a zero-shot manner.
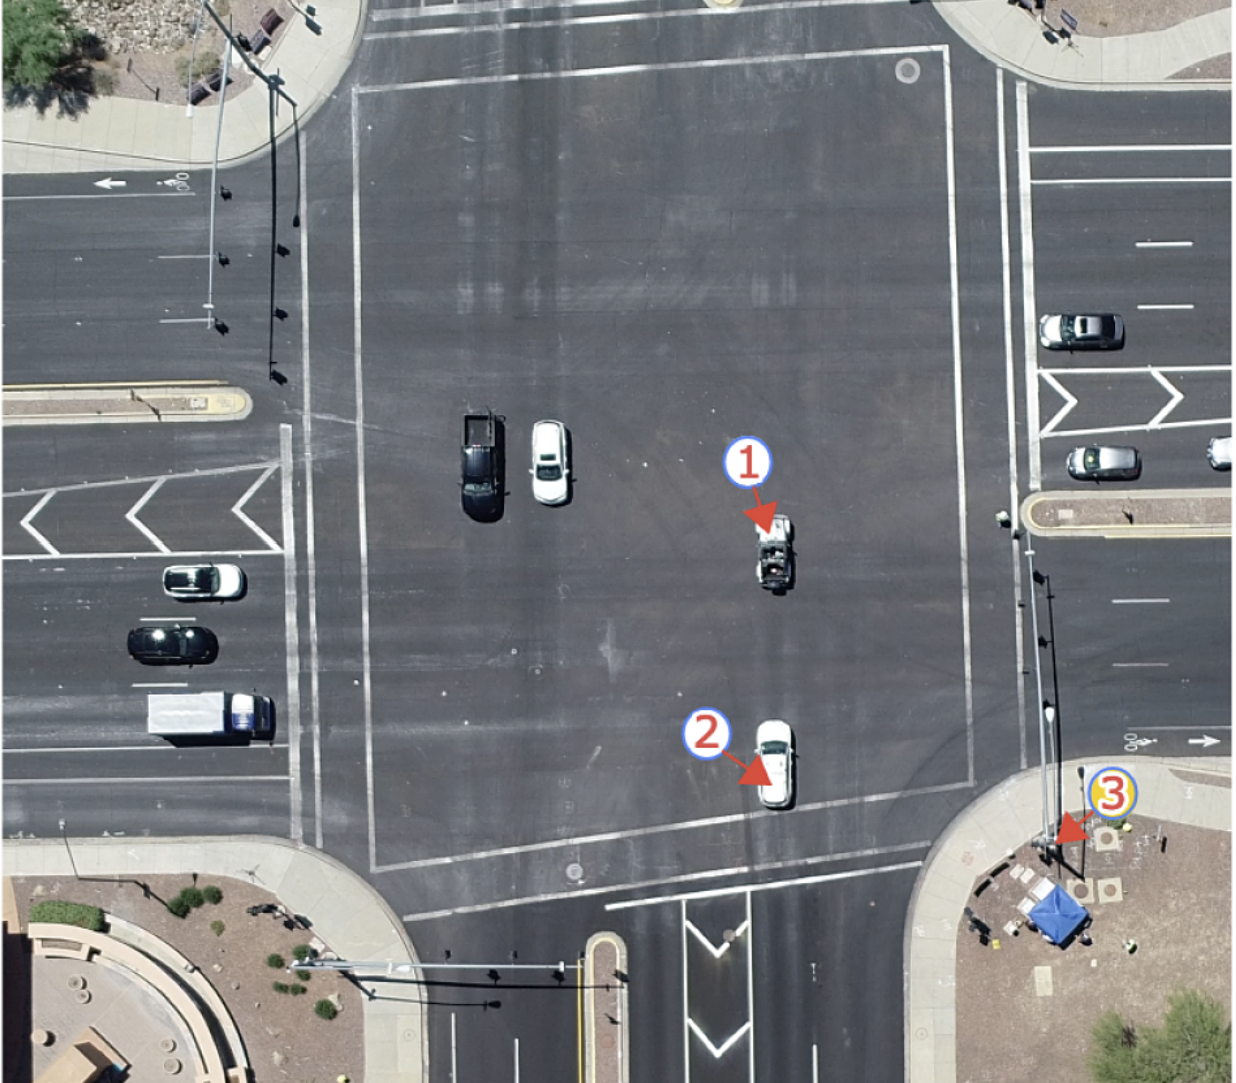
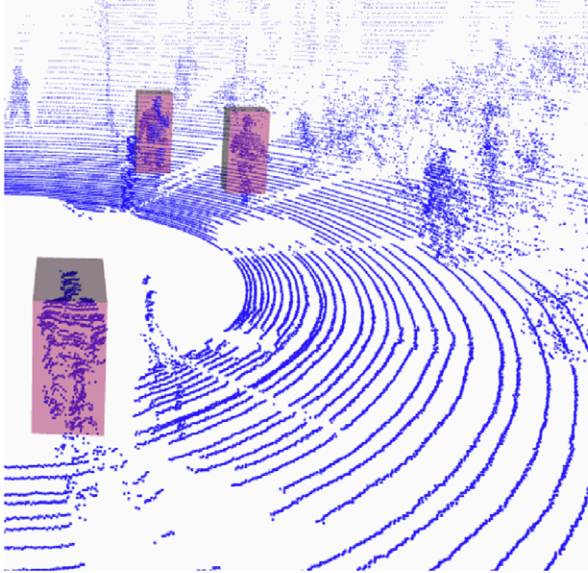
Evaluating Safety Metrics for Vulnerable Road Users at Urban Traffic Intersections Using High-Density Infrastructure LiDAR System Prabin Kumar Rath, Blake Harrison, Duo Lu, Yezhou Yang, Jeffrey Wishart, Hongbin Yu SAE World Congress Experience, 2024
Real-time VRU safety metrics evaluation strategies for urban traffic intersections.
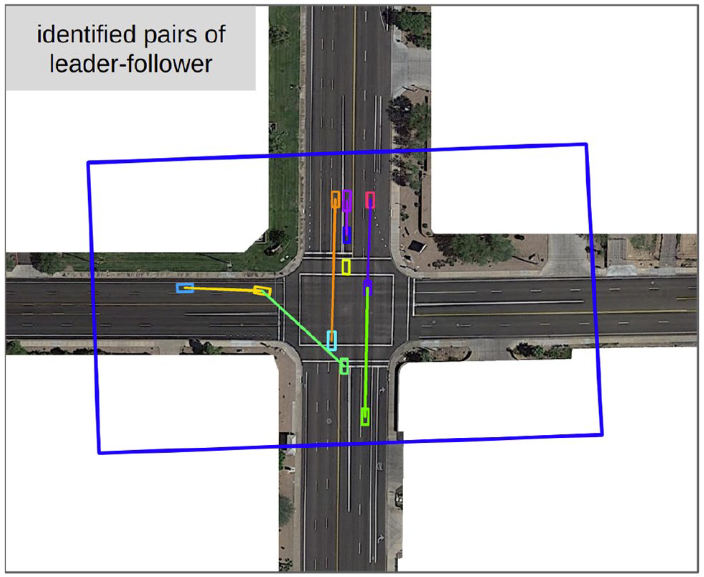
Validation and Analysis of Driving Safety Assessment Metrics in Real-world Car-Following Scenarios with Aerial Videos
Duo Lu, Sam Haines, Varun Chandra Jammula, Prabin Kumar Rath, Hongbin Yu, Yezhou Yang, Jeffrey Wishart SAE World Congress Experience, 2024
Leader-follower pair identification and metrics evaluation from aerial drone videos.
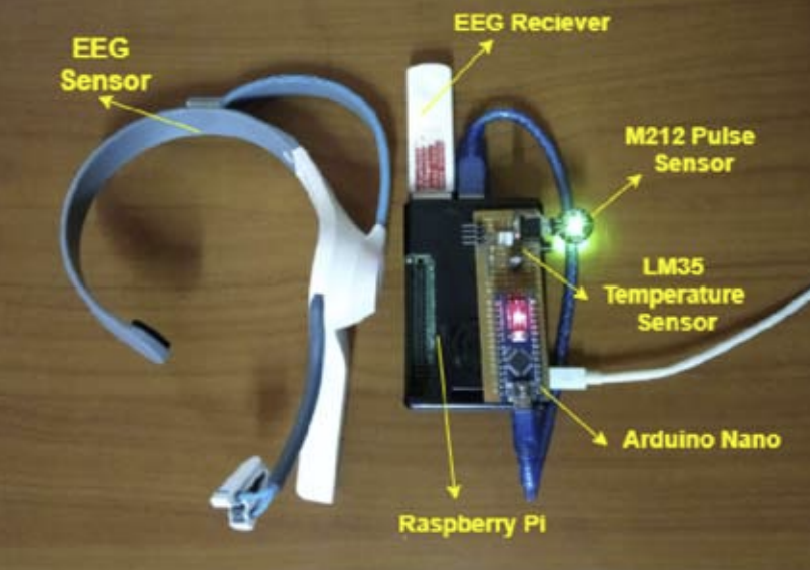
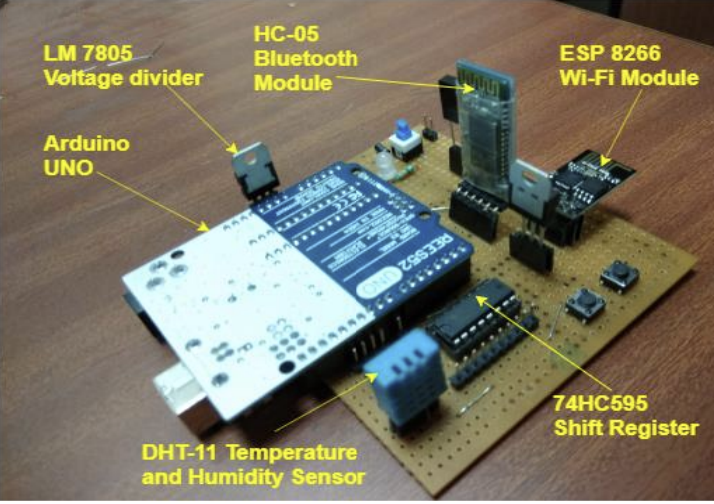
Design and Performance Analysis of an IoT Based Health Monitoring System for Hospital Management Prabin Kumar Rath, Neelam Mahapatro, Subham Sahoo and Suchismita Chinara IEEE International Conference on Computing Communication and Intelligent Systems, 2021
An IoT health kit for hospitals to assist doctors with medical diagnosis.
Real-time moving object detection and removal from 3D pointcloud data for humanoid navigation in dense GPS‐denied environments Prabin Kumar Rath, Alejandro Ramirez-Serrano, and Dilip Kumar Pratihar Engineering Reports, 2020 International Conference on Digital Image Computing: Techniques and Applications (DICTA), 2020
Detection and Tracking of Moving Objects (DATMO) algorithm for robot navigation in dynamic environments.
Automation System for Secure Remote Control and Surveillance Prabin Kumar Rath, Neelam Mahapatro and Soumya Nandan Mishra IEEE International Conference on Computer Electrical & Communication Engineering, 2020
Room Automation Module for switching electrical appliances remotely through Web, Bluetooth, and IR.
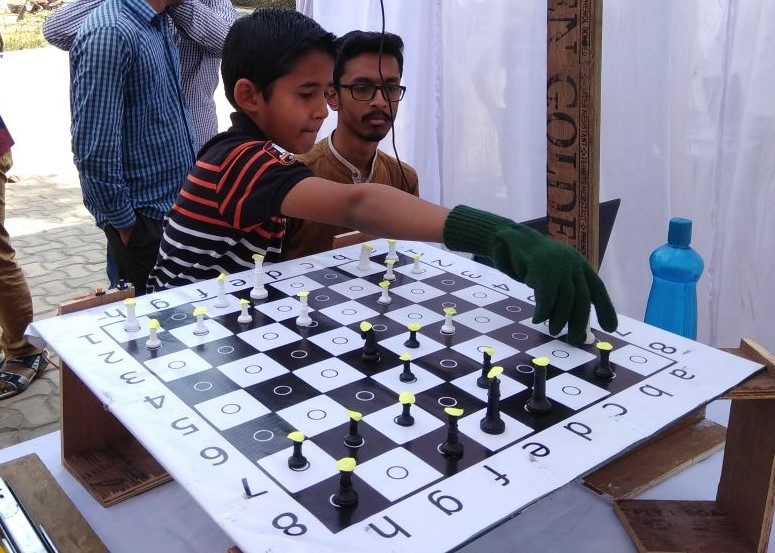
Autonomous Chess Playing Robot Prabin Kumar Rath, Neelam Mahapatro, Prasanmit Nath and Ratnakar Dash International Conference on Robot & Human Interactive Communication (RO-MAN), 2019
— Listed under top 10 projects in Quest Ingenium 2018
A robot for playing the game of chess physically with an user. Powered with strong chess engines and interactive UI it provides all virtual game features while ensuring the authenticity of the original board game.
Trajectory optimization for the cart pole swing-up problem using Direct collocation, and balancing the inverted pendulum on the cart using LQR control.
Simple LSTM model for classifying colloquial english sentences onto motion commands. Curated text to command dataset for model training using Tensorflow.
4-DOF Cube Stacking Arm Arizona State University, 2023
Customized replica of Turtlebot arm for pick and place tasks. ROS Control and MoveIt stack. Gym compatible environment for training RL agent in Gazebo.
A Bluetooth controlled robot with on board FSR (Force Sensitive Resistor) for weight detection. It has indication LEDs to prompt the user about the detected weights.